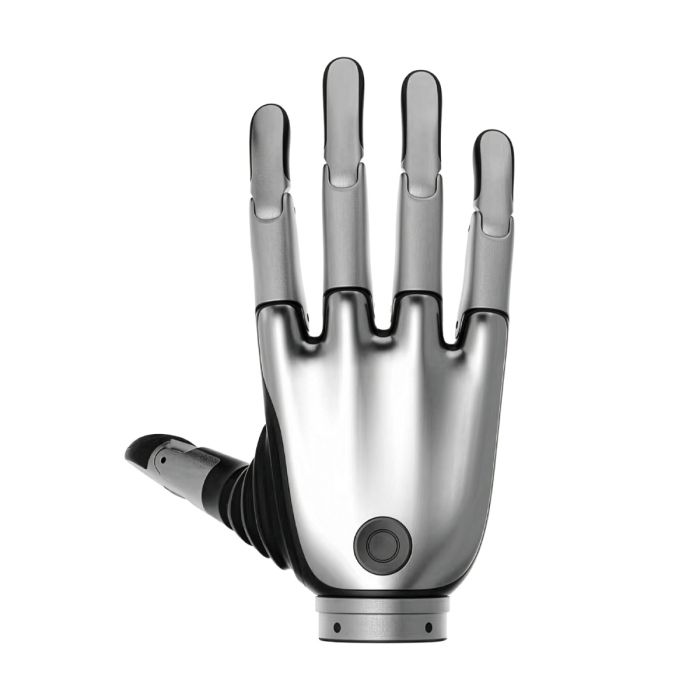
Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL)
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 2 TOUCH (LEFT)
- PART #:
- XTL
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Touch-Left
Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL)
A hand that only moves is a mechanism. A hand that can also report what it touches becomes a research instrument. The Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) is the tactile version of BrainCo's second-generation bionic hand, and it is meant for teams that want to study grasping, not just perform it.
Robots USA supplies the Brainco Revo 2 Touch left hand to robotics labs, integrators and humanoid developers. Robots USA quotes each order, arranges delivery and supports the hand after it ships.
Background
BrainCo and the Revo 2 lineage
BrainCo is the brand behind the Revo line of bionic hands. According to the published source, the Revo 2 is a bionic dexterous hand for robot integration and research. It is the second generation of the line; the earlier BrainCo Revo 1 Intelligent Dexterous Bionic Hand remains a separate product.
The Revo 2 generation comes in three versions, each with a left and a right hand. The sources name Basic (XRL/XRR), Pro (XEL/XER) and Touch (XTL/XTR). This page covers the Touch left hand, code XTL. The full family sits in the BrainCo Revo 2 category, and related end effectors are listed in the Hands category.
Where the Touch version sits
The Touch version is the tactile edition of the family. It shares the Revo 2 platform with the other versions. That means the same count of active joints and the same communication options, according to the published source. The Touch version is the one to choose when your work depends on what the fingers feel, rather than only where they are.
The source describes the second-generation advanced and tactile versions as supporting three communication interfaces: RS485, CAN FD and EtherCAT. The interface is located below the wrist. For an integrator, that placement matters, because it decides how the cable leaves the forearm or wrist mount.
Technical Specifications
| Specification | Value |
|---|---|
| Version and side | Touch, left hand |
| Version code | XTL (the right hand is XTR) |
| Active joints | 6 (reported) |
| Degrees of freedom | 11 (reported) |
| Thumb | Two active DOF for abduction and adduction, plus one passive flexion/extension DOF |
| Other four fingers | Each has one active and one passive flexion/extension DOF |
| Pinch force | ≥15N |
| Control precision | 0.1° |
| Communication interfaces | RS485, CAN FD, EtherCAT |
| Interface location | Below the wrist |
| Software support | SDK for Linux, Windows and ROS workflows |
| Control and protection | Closed-loop servo control, custom gesture definitions, protection for current, stall, high temperature and collision |
| Default device ID (left hand) | 126 |
| Material, IP rating, cable length, fingertip force resolution, box contents | Not published; confirmed at quotation |
Specifications as published by a single source; confirmed against the datasheet at quotation.
What makes the Touch version different from the Basic and Pro versions?
The name says it: Touch is the tactile version. The Basic version (XRL/XRR) and the Pro version (XEL/XER) are the other two members of the family. The sources we hold do not detail the tactile sensor itself. They do not publish its technology, its resolution or its layout, and the fingertip force resolution is not published. We will not describe sensor behavior that the manufacturer has not documented. Request the datasheet with your quotation if tactile data is central to your project.
What the sources do confirm is the shared foundation. The interface below the wrist is documented for both the advanced and the tactile versions. All Revo 2 hands are described with 6 active joints and 11 degrees of freedom, with RS485, CAN FD and EtherCAT support. So moving from Pro to Touch should not mean rethinking your communication stack. Confirm this at quotation against the datasheet.
If you do not need touch feedback, the BrainCo Revo 2 Pro Dexterous Left Hand (XEL) or the BrainCo Revo 2 Basic Left Dexterous Bionic Hand (XRL) may fit your program better. Pick the Touch version when the sensing is the point of the work.
How does the Revo 2 Touch move, stay protected and connect?
The thumb carries two active degrees of freedom for abduction and adduction, plus one passive degree of freedom for flexion and extension. Each of the other four fingers has one active and one passive flexion/extension degree of freedom. In practice, six actuated joints drive a hand that moves through eleven degrees of freedom in total. The passive joints let the fingers conform to an object while a small number of motors do the driving.
The source lists a pinch force of at least 15N and a control precision of 0.1°. Both are single-source figures, so treat them as published values and have them confirmed against the datasheet. Control is closed-loop servo control, and the hand supports custom gesture definitions. Your team can define and store the postures that matter for its own tasks.
The hand also carries protections for current, stall, high temperature and collision conditions. Anyone who has run a dexterous hand through hundreds of grasp trials knows why. Stalled fingers and overheated motors end experiments. Built-in protection reduces that risk, although the manufacturer has not published thresholds or trip points, so ask for them if your duty cycle is demanding.
Three communication interfaces are supported: RS485, CAN FD and EtherCAT. That range lets you match the hand to a lab bench controller, a fieldbus-based machine or a humanoid's internal network. The interface sits below the wrist.
On the software side, the source reports SDK support for Linux, Windows and ROS workflows. For the left hand, the default device ID is 126, and the right hand uses 127. If you build a two-handed robot with an XTL and an XTR, the IDs separate the two hands on a shared bus from the start. Check the documentation for how to change the ID if your network design requires it.
Who is the Brainco Revo 2 Touch left hand for?
The first group is university and corporate research labs working on manipulation, haptics and learning-based grasping. They need a hand that can sense contact and accept commands over standard interfaces. The second group is humanoid robot developers who want a left hand with a documented bus interface and ROS support. The third is industrial R&D teams prototyping assembly or handling tasks that need more than a two-finger gripper.
Many projects need two hands. The matching right hand is the Brainco Revo 2 Touch Biomimetic Dexterous Right Hand (XTR). If your application does not call for tactile data, consider the Pro or Basic versions instead, since they share the same platform without the sensing focus.
What is the Brainco Revo 2 Touch left hand used for?
- Humanoid robot integration. Fit a left hand with six active joints to a humanoid platform over RS485, CAN FD or EtherCAT.
- Manipulation research. Run grasp and in-hand manipulation experiments on a hand with eleven reported degrees of freedom.
- Tactile and haptics studies. Use the tactile version to investigate how contact information improves grasping.
- Gesture programming. Define custom gestures for repeatable postures and demonstrations.
- ROS-based development. Build and test control software with SDK support for Linux, Windows and ROS.
- Bimanual systems. Pair the left hand with the right-hand Touch version for two-handed work.
Pricing and Availability
We do not publish prices on this page. Request a quotation from Robots USA and tell us your quantity, your target controller and your application. Delivery, customs and support are arranged with the quotation. Everything we can state about this hand from published sources is available on this page.
Frequently Asked Questions
Is this the left or the right hand?
This is the left hand, version code XTL. The right-hand Touch version is coded XTR and is a separate product.
Which communication interfaces does it support?
The source lists RS485, CAN FD and EtherCAT. The interface is located below the wrist.
What software can I use with it?
The source reports SDK support for Linux, Windows and ROS workflows.
How many joints and degrees of freedom does it have?
The source reports 6 active joints and 11 degrees of freedom. The thumb has two active and one passive DOF, and each other finger has one active and one passive DOF.
What is the pinch force and control precision?
The published figures are a pinch force of at least 15N and a control precision of 0.1°. Both come from a single source and are confirmed against the datasheet at quotation.
Are the material, IP rating and cable length published?
No. The manufacturer has not published the material, the IP rating, the cable length, the fingertip force resolution or the box contents. They are confirmed at quotation.
Where can I buy the Brainco Revo 2 Touch left hand and what does it cost?
You can buy it through Robots USA by requesting a quotation. We do not list a price on this page; the quotation covers the cost, delivery and support.
Summary
A hand that can feel changes what a robotics team can learn. The Brainco Revo 2 Touch left hand (XTL) combines the Revo 2 platform, with its reported 6 active joints and 11 degrees of freedom, with a tactile focus, three industrial interfaces, SDK support for Linux, Windows and ROS, and protection against current, stall, temperature and collision faults. Several details remain unpublished and are confirmed at quotation. To specify, quote and order this hand from Robots USA, this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
What's included
Videos