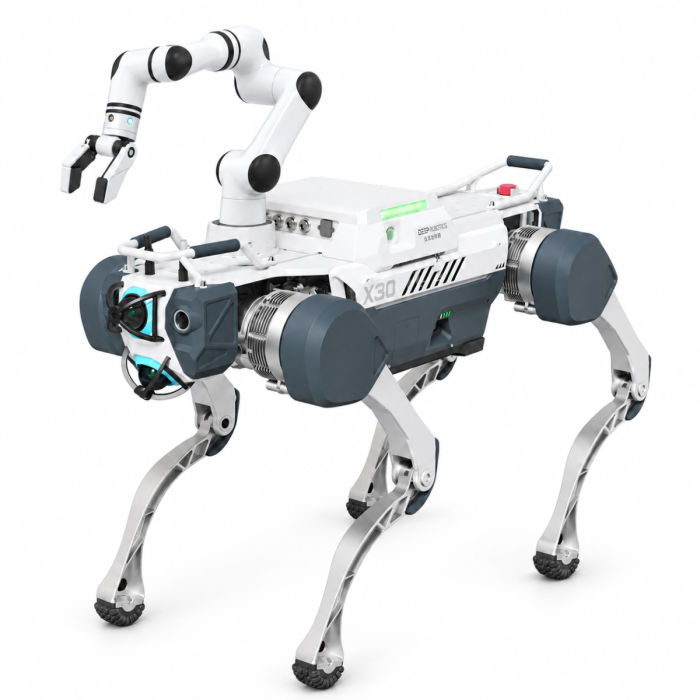
Deep Robotics X30 RealMan RML63-6F-V Robot Arm + Six-Dimensional Force+Gripper
In stock
- BRAND:
- DEEP ROBOTICS
- PART #:
- RML63-6F-V
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Deep-Robotics-X30-RealMan-RML63-6F-V
Deep Robotics X30 RealMan RML63-6F-V Robot Arm + Six-Dimensional Force+Gripper
Deep Robotics X30 RealMan RML63-6F-V Robot Arm + Six-Dimensional Force+Gripper
Deep Robotics X30 RealMan RML63-6F-V Robot Arm + Six-Dimensional Force+Gripper is a Deep Robotics-compatible accessory for X30. It is intended for robotics inspection, public-safety, emergency-response, industrial, or field-operation deployments where compatible X30 and/or M20 systems need additional capability.
Compatibility
- Compatible platform(s): X30
- Source/supplier brand: RealMan
- Model: RML63-6F-V
Specifications
【Arm】:
Degree of freedom: 6
Rated load: 5 kg
Body weight: 7.3 kg
Repeat positioning accuracy :± 0.05mm
Working radius: 638.5mm
Six-dimensional power range: 200 N/7 Nm
Six-dimensional force accuracy :< 0.1% FS
Supply voltage: DC 20-30V, rated DC24V
Power consumption: Maximum power consumption ≤200W, comprehensive power consumption ≤100W
Protection grade: IP54 (Mechanical arm body)
Material: Aluminum alloy
Controller: Integrated
Communication methods: WIFI/Network port/USB serial port/RS485
Control method: Drag-and-drop teaching/teaching device/API/JASON
Joint range of motion: J1 ± 178°,J2 ± 130°,J3 ± 135°
Joint range of motion: J4 ± 178°,J5 ± 128°,J6 ± 360°
Maximum joint speed: J1 - J2 ± 180°,J3 - J6 225°/s
【Depth Camera】:
Field of view: 87° (horizontal) *58° (vertical)
Depth distance: 0.25-2.5 meters
Relative accuracy: < 2% @ 2m
Camera principle: Binocular structured light
Supported operating systems: Windows 10/Android8/Ubuntu 18.04
Interface form: USB Type-C
Power consumption: Average power consumption < 2.3W, maximum power consumption < 5.0W (the duration for every 33ms in operation is ≤3ms)
【Gripper】:
<s:1> Control interface: RS485
<s:1> Opening size: 70mm
Weight: 231g
Youdaoplaceholder0 Clamping force: 0-20N
Force control accuracy: ±1N
Operating voltage: 7-9V
Maximum current: 1.5A
<s:1> Repeat positioning accuracy: ±0.5mm
<s:1> Clamping force resolution: 0.5N
Maximum speed: 70mm/s
Integration Notes
Robot(Power+Control)
Controllor(Image+Control)
Pricing and Availability
Availability is subject to confirmation before fulfillment.