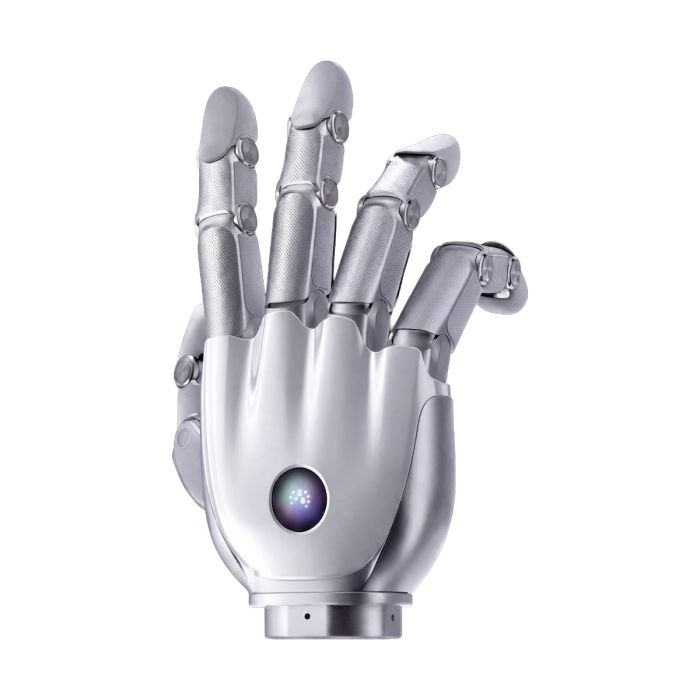
BrainCo Revo 3-21 V-Touch Robot Hand
In stock
- MARCA:
- BRAINCO
- MODELO:
- REVO 3-21 V-TOUCH
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-3-V-Touch
BrainCo Revo 3-21 V-Touch Robot Hand
A secure grasp is only part of a manipulation experiment; understanding the contact can matter just as much. The BrainCo Revo 3-21 V-Touch Robot Hand brings those priorities together through a reported combination of articulated movement, palm sensing, and fingertip vision-tactile sensing. For a buyer, the important question is not simply whether a hand can hold an object, but whether its mechanical and sensing architecture fits the controller, test procedure, and integration work the project requires.
Robots USA sells this product for robotics projects in the United States. Robots USA is your point of contact for a configuration-specific quotation and for arranging delivery and support. The quotation should identify the requested hand version and clarify the integration requirements before procurement, particularly where the published specification does not describe the supplied accessories or environmental limits.
Background
BrainCo and the Revo family
The supplied source describes BrainCo as a Hangzhou-based brain-computer interface company and identifies Revo 3 as its third-generation robot dexterous hand. That background establishes the manufacturer's positioning, but it does not establish that this product includes a brain-computer interface or supports neural control. Buyers should distinguish company history from the capabilities specified for the hand they are ordering.
The source names Revo 3 U21, Revo 3 U21F, Revo 3 U21T, and Revo 3 U21VT. The detailed version-specific figures available here belong to Revo 3 U21VT. They should not be transferred to another named version, nor should the presence of several versions be taken as evidence that their sensing, accessories, or electrical requirements are interchangeable.
Positioning around movement and contact
Per the published description, the Revo 3 is a biomimetic dexterous hand intended for industrial automation, scientific research, and advanced robotics manipulation. For Revo 3 U21VT, the source reports direct-driven, backdrivable joints alongside a palm piezoresistive array and fingertip vision-tactile sensing. This makes movement and contact sensing distinct parts of the platform's evaluation rather than reducing selection to grip force alone.
In robotics generally, tactile information can help researchers investigate contact changes during grasping and manipulation. Whether a particular control strategy succeeds still depends on software, object properties, mounting, and validation. The published sensing description is a reason to investigate those workflows, not a guarantee of autonomous manipulation performance.
Technical Specifications
| Specification | Value |
|---|---|
| Total degrees of freedom | Reported: 21 (Direct-driven and backdrivable) |
| DoF distribution | Reported: Four fingers × 4 DoF, thumb × 5 DoF |
| Hand dimensions | Reported: 216 × 108 × 50 mm |
| Supply voltage | Reported: 16–85 V |
| Max current | Reported: 10 A (24 V) |
| Max active grip force | Reported: ≥100 N |
| Max fingertip pinch force | Reported: ≥25 N |
| Total hand payload | Reported: 20 kg |
| Four-finger payload | Reported: 5 kg |
| Repeatability | Reported: 0.1° |
| Joint open/close time | Reported: 0.33 s |
| Max grasping diameter | Reported: 150 mm |
| Communication interface | Reported: EtherCAT / CAN FD / RS-485 |
| Communication frequency | Reported: 500 Hz |
| Onboard sensors | Reported: IMU (Mainboard), Temperature (Mainboard) |
| Tactile type | Reported: Palm piezoresistive array + fingertip vision-tactile |
| Tactile array taxels | Reported: 336 points (piezoresistive) + 2000 markers (vision-tactile) |
| Motion capability | Reported: Full score on the Kapandji opposition test; covers 33 grasp types (Feix GRASP taxonomy) |
| Revo 3 durability rating | Reported: over 1,000,000 joint flex cycles |
| Published power supply recommendation | Reported: stable 24V DC power supply with a power rating of at least 100W |
| Weight | Not published in the supplied sources; confirmed at quotation |
| IP rating | Not published in the supplied sources; confirmed at quotation |
| Operating temperature range | Not published in the supplied sources; confirmed at quotation |
| What is in the box | Not published in the supplied sources; confirmed at quotation |
| Operating noise level | Not published in the supplied sources; confirmed at quotation |
| Fingertip camera specifications | Not published in the supplied sources; confirmed at quotation |
Specifications are as published in the supplied source and are confirmed against the datasheet at quotation.
What should buyers evaluate beyond grip force?
Start with the contact information your application needs. The published Revo 3 U21VT specification distinguishes palm piezoresistive sensing from fingertip vision-tactile sensing. These are different sensing descriptions, and the reported points and markers should not be treated as interchangeable measurements of resolution. Fingertip camera specifications are unpublished in the supplied sources and are confirmed at quotation; image quality or deformation sensitivity should not be inferred from marker count.
Mechanical capability also needs context. Per the published specification, total hand payload and four-finger payload are separate ratings. Neither should be substituted for active grip force or fingertip pinch force. A procurement review should identify the intended grasp, object surface, orientation, and supporting robot so the relevant rating can be checked against the actual task.
The source reports cross-platform C/C++ and Python SDKs compatible with Linux and Windows. It also reports EtherCAT / CAN FD / RS-485 interfaces for Revo 3 U21VT. Ask Robots USA to clarify the required interface configuration, software access, and connection hardware at quotation. A published interface list does not establish which cables, adapters, or integration examples are included.
Finally, separate component specifications from system-level results. The published source reports a full score on the Kapandji opposition test and coverage of 33 grasp types in the Feix GRASP taxonomy. Those statements describe reported motion capability; they do not establish a success rate for your object set or a validated production cycle.
Who is BrainCo Revo 3-21 V-Touch Robot Hand for?
This hand is worth evaluating for research teams studying dexterous manipulation, engineering groups developing contact-aware control, and automation teams investigating tasks that may need an articulated hand. Its reported combination of palm and fingertip sensing is particularly relevant when contact data is part of the experiment rather than merely a secondary observation.
For industrial buyers, selection should begin with a defined task and acceptance criteria. The weight, IP rating, operating temperature range, and operating noise level are unpublished in the supplied sources and are confirmed at quotation. These gaps matter when assessing robot loading, environmental exposure, and workplace suitability; they should be resolved before committing to an installation.
Buyers comparing configurations can also review the BrainCo Revo 3-21 Basic Robot Hand and BrainCo Revo 3-21 Touch Robot Hand. The available fact sheet does not establish their comparative specifications, so it does not support recommending either as a better fit for a particular segment. Ask Robots USA for a version-specific comparison rather than assuming that the product names establish the differences.
What is BrainCo Revo 3-21 V-Touch Robot Hand used for?
- Grasp research: Evaluate hand postures and object contact within a controlled experimental setup.
- Tactile perception studies: Investigate how contact information can inform robotic manipulation.
- Manipulation controller development: Test approaches to coordinated finger movement and grasp adjustment.
- Automation feasibility testing: Determine whether an articulated hand suits a defined handling task.
- Robot integration research: Assess mounting, power, communications, and software requirements as a complete system.
- Repeatable laboratory experiments: Develop documented procedures for comparing manipulation strategies across test objects.
Pricing and Availability
Request a quotation from Robots USA for the required configuration. Include your application, intended robot platform, preferred communication interface, and any sensing or software requirements so the proposal can address integration rather than just identify the hand. Box contents are unpublished in the supplied sources and are confirmed at quotation.
Delivery, customs, and support are arranged by Robots USA with the quotation. Submit your requirements through the quotation request available on this page.
Frequently Asked Questions
Which version do the listed figures describe?
The version-specific figures are reported for Revo 3 U21VT. The source also names Revo 3 U21, Revo 3 U21F, and Revo 3 U21T, but does not provide equivalent comparative figures in the supplied fact sheet.
What tactile sensing does it have?
The published Revo 3 U21VT specification reports a palm piezoresistive array and fingertip vision-tactile sensing. Fingertip camera specifications are unpublished in the supplied sources and are confirmed at quotation.
Are the joints backdrivable?
Per the published specification, Revo 3 U21VT has 21 degrees of freedom described as direct-driven and backdrivable. Application-specific control and safety requirements still need an integration review.
What software environments are supported?
The source reports C/C++ and Python SDKs compatible with Linux and Windows. Confirm software delivery, documentation, and the required interface workflow with Robots USA at quotation.
What power supply should I plan for?
The published recommendation is a stable 24V DC power supply with a power rating of at least 100W. Confirm the electrical integration and supplied power accessories at quotation rather than assuming a power supply is included.
Is it suitable for wet or dusty environments?
The IP rating and operating temperature range are unpublished in the supplied sources and are confirmed at quotation. Environmental suitability should not be assumed without those details.
Where can I buy BrainCo Revo 3-21 V-Touch Robot Hand and what does it cost?
Request a configuration-specific quotation from Robots USA through this page. Robots USA will address the requested configuration and arrange delivery, customs, and support with the quotation.
Summary
Contact is the thread connecting this hand's evaluation: how the fingers move, how the object is held, and what sensing is available during that interaction. The reported Revo 3 U21VT specification provides a basis for reviewing those questions, while unpublished environmental, camera, and package details remain procurement checks. For a quotation that connects the published capabilities to your integration requirements, this page is the starting point.