BrainCo Revo 1 Intelligent Dexterous Bionic Hand
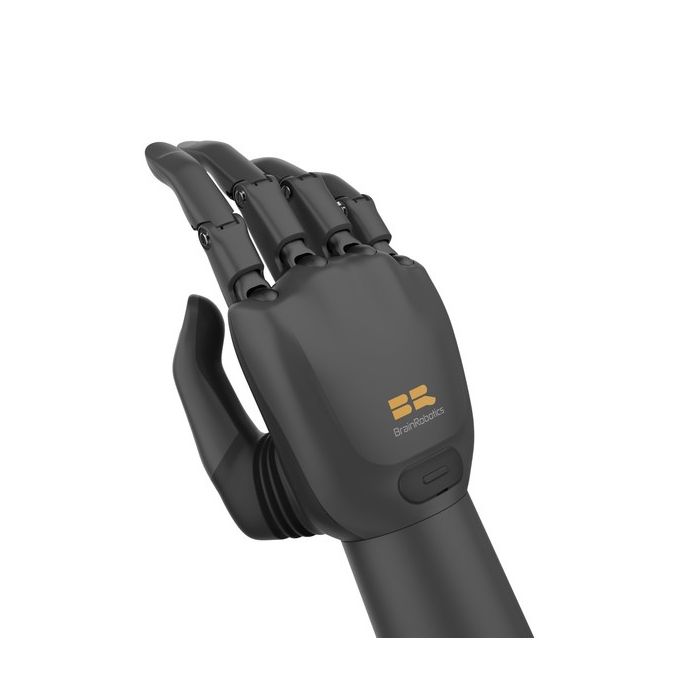
The BrainCo Revo 1 Intelligent Dexterous Bionic Hand is a robotic dexterous hand platform from BrainCo, a brain-computer-interface and human-machine-interface company that publicly lists “BrainCo Bionic Dexterous Hand Revo1” among its product lines on its official website. BrainCo positions itself as a company working across bionic hands, bionic knees, neurotechnology, and AI-oriented robotics solutions.
In stock
- MARCA:
- BRAINCO
- NÚMERO DE PIEZA #:
- Intelligent Dexterous Bionic Hand
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Dexterous-Bionic-Hand
BrainCo Revo 1 Intelligent Dexterous Bionic Hand
A successful grasp begins before contact: the integration team must decide how motion, object interaction, and control software will work together. The BrainCo Revo 1 Intelligent Dexterous Bionic Hand brings those questions into a hand-shaped platform, described in the published specification as a biomimetic dexterous hand. For a buyer, the important distinction is between an appealing demonstration and a configuration that can be evaluated against a real task. Joint architecture, startup behavior, software access, and the exact sensing SKU all belong in that evaluation.
Robots USA sells this product for projects supplied in the United States. Robots USA is the contact for quotation, configuration review, delivery arrangements, and support coordination. A useful inquiry identifies the intended application, host platform, preferred hardware variant, and whether tactile sensing is required. That makes the quotation a technical purchasing document rather than simply a request for a product name.
Background
BrainCo's origins and development context
According to the published company account, BrainCo was founded in 2015, incubated by the Harvard Innovation Lab, and based in Somerville, Mass., with a focus on non-invasive brain-computer interface technology. That background provides context for evaluating a bionic hand within human-machine interaction research. It does not, by itself, establish clinical suitability, certification, or a particular connection between this hand and a brain-computer interface.
Where Revo 1 fits
The published specification identifies Revo 1 Basic and Revo 1 Advanced as hardware variants and states that tactile sensing depends on the SKU. A Basic Touch SKU is also named in the supplied research, but its detailed configuration is not established. Buyers should therefore specify the requested hardware and sensing arrangement separately. The available evidence supports a discussion of the hand's architecture and control behavior, not a complete feature comparison between every version.
Technical Specifications
| Specification | Value per the published specification |
|---|---|
| Product type | Biomimetic dexterous hand |
| Hardware variants | Revo 1 Basic; Revo 1 Advanced; tactile sensing depends on the SKU |
| Active joints | 6 |
| Degrees of freedom | 10 |
| Maximum hand load | 30 kg |
| Five-finger grip force | 50 N |
| Thumb layout | Two active degrees of freedom: abduction/adduction and flexion/extension |
| Other finger layout | Each of the other four fingers has one active and one passive flexion/extension degree of freedom |
| Interface location and connector | Under the wrist; PAP-05V-S |
| Control modes | Position and Speed; to be confirmed against the datasheet at quotation |
| Turbo mode | After a stall, pauses for the configured stall duration, then continues gripping at 500 ms intervals |
| Power-on behavior | Automatic position calibration sweep |
| Device ID | Default 1; adjustable within 1 - 254 |
| LED customization | User-configurable colors and patterns |
| ROS 2 driver | Reported driver for Revo 2 / Revo 1 hand control |
| SDK examples | Reported Python and C/C++ examples for Revo 2 / Revo 1, Control Glove, and EMG Armband |
| Hand weight | Not published by the manufacturer; confirmed at quotation |
| Hand dimensions | Not published by the manufacturer; confirmed at quotation |
| IP rating | Not published by the manufacturer; confirmed at quotation |
| Box contents | Not published by the manufacturer; confirmed at quotation |
| Warranty-independent certifications | Not published by the manufacturer; confirmed at quotation |
Specifications are as published and are confirmed against the datasheet for the selected SKU at quotation; the available figures do not establish separate ratings for each variant.
How do active joints and passive motion affect Revo 1 evaluation?
Per the published specification, the thumb has active abduction/adduction and flexion/extension, while each remaining finger combines active and passive flexion/extension. This distinction matters when planning an experiment: a degree of freedom is not necessarily a separately commanded motion. Buyers should map the movements their task requires to the actual controllable joints before writing a control strategy.
The reported maximum hand load of 30 kg and five-finger grip force of 50 N describe different quantities. Neither should be treated as a universal object-handling guarantee. Object geometry, contact conditions, mounting, and the intended motion need to be reviewed independently. Ask Robots USA to confirm the rating definitions and applicable test conditions at quotation rather than treating a headline figure as an application approval.
What should be checked before integrating Revo 1?
Startup clearance deserves attention. According to the published specification, the hand automatically performs a position calibration sweep after power-on. A test fixture should account for that movement before power is applied. The reported Turbo mode also needs deliberate evaluation: after a finger stalls against an object, it pauses for the configured stall duration and then continues gripping at 500 ms intervals. That behavior should be considered alongside the application's contact and stop requirements.
Software access is reported through a ROS 2 driver and Python and C/C++ SDK examples covering Revo 2 / Revo 1. The examples also name Control Glove and EMG Armband, but this does not establish that either accessory is included. Confirm software versions, supported commands, electrical requirements, and the host interface before finalizing an integration plan. A connector model alone does not establish complete wiring or communications compatibility.
Who is BrainCo Revo 1 Intelligent Dexterous Bionic Hand for?
This product is relevant to robotics laboratories, university teaching teams, and integrators investigating hand-shaped manipulation. Their purchasing questions differ: a laboratory may prioritize repeatable experiments, a teaching team may need clear startup procedures, and an integrator may focus on mounting and software interfaces. These are general selection priorities, not claims of validated performance for this product.
Human-machine interaction researchers may also consider it for supervised experimental work. Buyers requiring tactile feedback should request an explicitly identified sensing SKU rather than assuming that Revo 1 Advanced or Basic Touch has a particular sensor arrangement. The evidence does not support recommending one variant over another on detailed performance grounds. The BrainCo Revo 1 category provides a starting point for reviewing the product family before requesting configuration confirmation.
What is BrainCo Revo 1 Intelligent Dexterous Bionic Hand used for?
- Grasp-planning research: Evaluate how a hand-shaped mechanism approaches objects in a controlled laboratory setting.
- Motion-control development: Investigate command sequences against the confirmed control functions of the selected configuration.
- Robotics education: Structure supervised lessons around joint architecture, calibration, and integration planning.
- End-effector integration studies: Assess mounting, clearance, wiring, and host-control requirements before broader deployment.
- Human-machine interaction experiments: Explore experimental input workflows after confirming the required software and accessories.
- Contact-behavior testing: Examine grasping and stall responses under documented test conditions and appropriate safeguards.
Pricing and Availability
Request a quotation from Robots USA for the exact variant and sensing configuration your project requires. Include the intended task, mounting arrangement, software environment, and any requested accessories so the scope can be reviewed. Robots USA arranges delivery, customs, and support with the quotation. Submit those requirements through the quotation option available on this page.
Frequently Asked Questions
Does Revo 1 have independently driven motion for every degree of freedom?
No: the published layout distinguishes active and passive motion, reporting 6 active joints and 10 degrees of freedom. Confirm the command mapping before designing individual joint-control experiments.
Does every version include tactile sensing?
The published specification says tactile sensing depends on the SKU. Request written confirmation of the selected configuration rather than inferring sensing capability from the version name.
What does the hand do when powered on?
Per the published specification, it automatically executes a position calibration sweep. Provide suitable clearance and confirm the startup procedure before operating it in a fixture.
Can developers use ROS 2 or Python?
A ROS 2 driver and Python and C/C++ SDK examples for Revo 2 / Revo 1 are reported. Confirm the available software package and its compatibility with your development environment at quotation.
Are the load and grip-force ratings interchangeable?
No. The published specification reports a maximum hand load of 30 kg and a five-finger grip force of 50 N; request the relevant definitions and conditions for your application.
What physical and compliance information is available?
The manufacturer has not published hand weight, hand dimensions, an IP rating, box contents, or warranty-independent certifications in the supplied sources. These details are confirmed at quotation before purchase or application approval.
Where can I buy BrainCo Revo 1 Intelligent Dexterous Bionic Hand and what does it cost?
Request a quotation from Robots USA. The quotation establishes the selected configuration, accessories, delivery arrangements, customs, and support without relying on assumptions about the package.
Summary
The useful question is not simply whether a hand can grasp, but whether its documented behavior fits the experiment or integration task. Revo 1's reported joint architecture, calibration routine, and development tools provide a basis for that review, while sensing configuration and unpublished physical details still require confirmation. For a configuration-specific discussion with Robots USA, this page is the starting point.