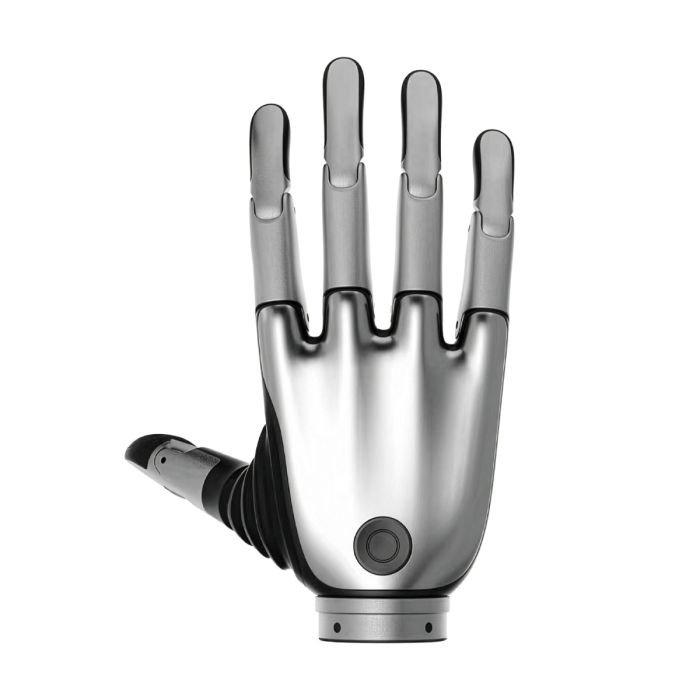
BrainCo Revo 2 Pro Dexterous Right Hand (XER)
In stock
- MARCA:
- BRAINCO
- MODELO:
- REVO 2 PRO
- NÚMERO DE PIEZA #:
- XER
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Pro
BrainCo Revo 2 Pro Dexterous Right Hand (XER)
A convincing grasp demonstration and a well-specified research platform are not the same thing. Selecting a hand means separating what is documented from what still needs verification on the intended robot. The BrainCo Revo 2 Pro Dexterous Right Hand (XER) is described in the published specification as a bionic dexterous hand for robot integration and research. Its Pro positioning makes controller connectivity an important part of the selection, while unanswered mechanical and sensing questions remain part of the engineering review.
Robots USA sells this product for robotics projects in the United States. Robots USA handles quotation requests and coordinates the supply requirements for the intended installation. Share your controller architecture, wrist interface, power arrangement, and research objectives so the quotation can address the configuration rather than just the product name.
Background
BRAINCO and the Revo 2 family
The supplied product information identifies BRAINCO as the brand and reports three Revo 2 versions: Basic, Pro, and Touch. Their published codes are XRL/XRR, XEL/XER, and XTL/XTR respectively. This page concerns the right-hand Pro product identified as XER; the other versions are comparison options, not interchangeable names for the same item.
The available fact sheet does not establish the company's history, manufacturing location, or product development timeline. Those details are not needed to distinguish the configurations, and they should not substitute for an integration assessment. The useful background here is the documented version structure and the differences in connectivity and electrical specifications.
Dexterity as an integration question
Per the published specification, Revo 2 provides 6 active joints and 11 degrees of freedom. These are different descriptors: a degrees-of-freedom count should not be read as a count of independently driven joints. For research teams, the practical question is how the available motion maps to the grasp strategies and control experiments they intend to develop.
The published SDK information reports Python/C support and compatibility with Linux/Windows/ROS systems. That gives software teams a starting point for assessing their development environment, but it does not establish compatibility with a particular robot, controller, or software release. Integration still requires review of the actual SDK and communication documentation.
Technical Specifications
| Specification | Basic | Pro | Touch |
|---|---|---|---|
| Version code | Reported: XRL/XRR | Reported: XEL/XER | Reported: XTL/XTR |
| Communication interface | Reported: 485, CANfd | Reported: 485, CANfd, EtherCAT | Reported: 485, CANfd, EtherCAT |
| Supply voltage | Reported: 12-28V | Reported: 12-64V | Reported: 12-64V |
| Static current | Reported: 65 mA @24V | Reported: 115 mA @24V | Reported: 115 mA @24V |
| Maximum current | Reported: 4.6 A @24V | Reported: 4.65A @24V | Reported: 4.65A @24V |
| Repetitive control precision | Reported: 0.1° | Reported: 0.1° | Reported: 0.1° |
These are specifications as published; they are confirmed against the datasheet at quotation.
The published family specification reports a weight of 383 g and a height of 160 mm, measured from the palm base to the middle fingertip. It also reports a maximum opening and closing distance of 100mm(from thumb to index finger). These are family-level entries; the manufacturer has not published a right-hand specific weight, which is confirmed at quotation.
Per the published specification, full fist grip force is ≥50N, pinch force is ≥15N, and maximum payload is ≥20kg. These distinct entries should not be treated as interchangeable measures of grasp performance. The specification also reports flexion/extension speed of ≤0.65s and operating noise of ≤50dB at 50cm; test conditions should be checked before using these figures as acceptance criteria.
The published operating-temperature entry is -10 - 40℃ / 90%RH. Reported smart protection includes current protection, stall protection, high-temperature protection, and anti-collision protection. OTA online upgrades are also reported. The manufacturer has not published an IP rating or service life; both are confirmed at quotation rather than inferred from the environmental or protection entries.
Per the published specification, standard colors are Space Gray and Silver, with bulk color customization supported. The manufacturer has not published wrist flange dimensions or a tactile sensing specification; these are confirmed at quotation. Neither mounting suitability nor tactile capability should be assumed from the product's appearance or version name.
What does the Revo 2 Pro add over Basic?
The clearest documented distinction is connectivity. Per the published comparison, Pro adds EtherCAT to the 485 and CANfd interfaces listed for Basic. For a team already working with an EtherCAT architecture, that is a concrete reason to evaluate Pro rather than choosing only on the basis of its tier name.
The published comparison also gives Pro a 12-64V supply range, versus 12-28V for Basic. Its reported current entries differ as well, so the wider voltage range is not a reason to skip power-system planning. Review the available supply, protection, wiring, and controller requirements together; none of these entries establishes a ready-made connection to a specific robot.
Repetitive control precision is reported as 0.1° for all three versions. The supplied evidence therefore does not justify describing Pro as more precise than Basic. Choose on documented differences and project requirements, not an assumed improvement attached to the word “Pro.”
Who is BrainCo Revo 2 Pro Dexterous Right Hand (XER) for?
This product is relevant to robotics laboratories, university teams, and integrators evaluating a right-hand end effector for manipulation research. Its reported EtherCAT interface makes Pro particularly worth considering when that communication option is part of the planned architecture. Teams should still confirm mechanical fit and software requirements before treating the hand as an installation-ready component.
If EtherCAT is not required and the reported Basic electrical specifications suit the project, consider the BrainCo Revo 2 Basic Right Dexterous Bionic Hand (XRR). For a project requiring a left-hand Pro configuration, review the BrainCo Revo 2 Pro Dexterous Left Hand (XEL). The fact sheet does not establish mirrored mounting dimensions or identical side-specific weight.
Teams whose work depends on tactile feedback can also review the Brainco Revo 2 Touch Biomimetic Dexterous Right Hand (XTR), but the supplied evidence does not define its sensing capabilities. Request sensing documentation before choosing it for that purpose.
What is BrainCo Revo 2 Pro Dexterous Right Hand (XER) used for?
- Grasp strategy research: Evaluate how hand motion and object geometry affect a planned manipulation task.
- Controller development: Investigate command handling within a documented communication architecture.
- Robot integration studies: Assess wrist mounting, power distribution, and hand placement before deployment.
- Manipulation software experiments: Develop research workflows around verified SDK functions and supported environments.
- Coordinated manipulation: Explore tasks involving another manipulator after confirming both configurations and control requirements.
- Teaching and demonstrations: Use a supervised research setup to illustrate the relationship between grasp planning and physical interaction.
Pricing and Availability
Request a quotation from Robots USA for the XER configuration and the documentation needed for your project. Per the published package specification, Pro includes one dexterous hand, one 485/CANFD communication cable, one power cable, and one EtherCAT communication cable; confirm these contents with the quotation. Robots USA arranges delivery, customs, and support with the quotation. Submit your requirements through the quotation option available on this page.
Frequently Asked Questions
Is this the right-hand Pro version?
The product is identified as the right-hand XER configuration. The published version table reports XEL/XER as the Pro codes.
Which communication interfaces are listed?
Pro is reported to support 485, CANfd, and EtherCAT. Confirm the interface documentation and controller requirements at quotation.
Does the SDK support ROS?
The published SDK description reports compatibility with Linux/Windows/ROS systems and support for Python/C. Specific software versions and available functions are not established by the supplied fact sheet.
Does Pro include tactile sensing?
The manufacturer has not published a tactile sensing specification in the available sources; it is confirmed at quotation. Do not assume sensing capabilities from the Pro designation.
Will it fit my robot wrist?
The manufacturer has not published wrist flange dimensions; they are confirmed at quotation. Provide the robot's mounting information for comparison before selecting the hand.
Is an environmental protection rating available?
The manufacturer has not published an IP rating; it is confirmed at quotation. The reported operating-temperature entry does not establish resistance to dust or water.
Where can I buy BrainCo Revo 2 Pro Dexterous Right Hand (XER) and what does it cost?
Request a quotation from Robots USA for this configuration. Robots USA will address the product requirements, delivery, customs, and support in the quotation.
Summary
The decision is not simply whether a robot hand can demonstrate a grasp, but whether its documented capabilities fit the intended research platform. Pro's reported connectivity and electrical specifications provide useful selection criteria, while mounting, tactile sensing, right-hand weight, environmental protection, and service life need confirmation. For a requirements-based quotation from Robots USA, this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
Feature
1. High quality and stability – five years of product iteration and professional production lines.
2. Lightweight (383 grams), with 5 kg active grip force, 20 kg single-hand load capacity, and a grip-to-weight ratio of 53.
3. Ergonomic Bionic Design – supports curved surface grasping with anti- collision finger design.
4. Multi-dimensional tactile perception – pressure, friction, direction, proximity, and surface texture.
5. High Sensitivity Tactile Perception – max resolution of 0.01N.
6. Wide voltage support – 64V.
7. Universal Interfaces – RS485 & CAN-FD, and EtherCAT.
8. Standard Protocols and SDKs – Modbus & Protobuf protocols, SDKs for Python / C / ROS.