Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL)
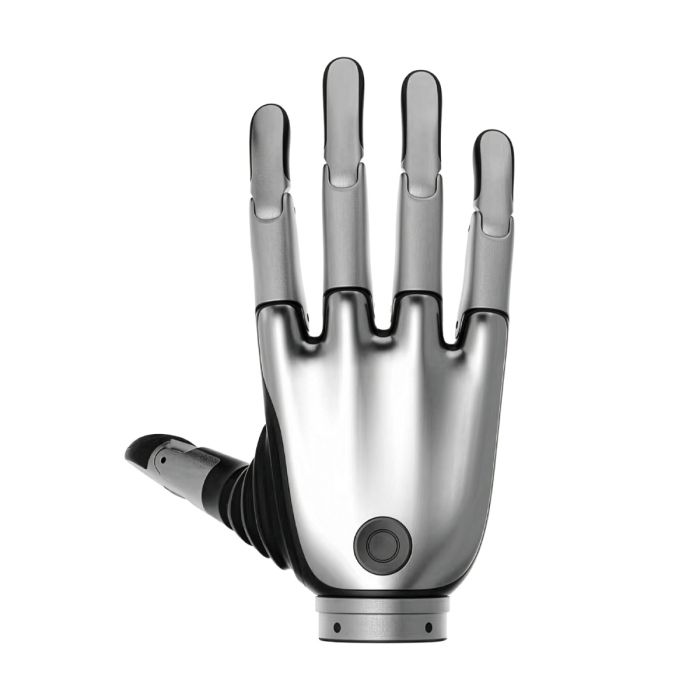
In stock
- MARCA:
- BRAINCO
- MODELO:
- REVO 2 TOUCH (LEFT)
- NÚMERO DE PIEZA #:
- XTL
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Touch-Left
Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL)
A robot integration project can stall at the wrist: the hand must fit the control architecture as well as the task. The Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) is described in the published specification as a bionic dexterous hand for robot integration and research. For a buyer, the useful starting point is not an assumed application-ready package, but a review of its reported articulation, communication interfaces, and control provisions against the intended platform.
Robots USA sells this product for projects in the United States. Robots USA handles the quotation and coordinates delivery and support arrangements around the selected configuration. Buyers should identify their robot platform, intended grasping tasks, and software environment when requesting a quotation so that the hand, connection requirements, and scope of supply can be reviewed together.
Background
BRAINCO and the Revo version structure
The supplied product identity places this hand in the BRAINCO range. The published version listing identifies Basic as XRL/XRR, Pro as XEL/XER, and Touch as XTL/XTR. This page concerns the left-hand XTL configuration, not a interchangeable specification for every member of that range. Version codes matter when preparing a purchase request, particularly when a project requires a specific side or a matched configuration.
The available fact sheet does not establish a company history, a launch chronology, or a complete comparison of the versions. Those details should not be inferred from the Revo name. For procurement, an exact model reference and an agreed specification are more useful than an unsupported account of the product's lineage.
Articulation and control positioning
Per the published specification, the Revo 2 platform provides 6 active joints and 11 degrees of freedom. That distinction is important: an overall degree-of-freedom count should not be read as a count of independently commanded axes. Active and passive motion play different roles in an articulated hand, and an integration team should map its intended gestures to the documented control model.
The same source reports closed-loop servo control and custom gesture definitions. These provisions make command structure and gesture planning relevant evaluation topics, but they do not establish performance for any particular object or task. A demonstration using representative objects remains a sensible part of a research equipment assessment.
Technical Specifications
| Specification | Value |
|---|---|
| Touch version codes | Reported: XTL/XTR; this product is XTL |
| Active joints | Reported: 6 |
| Degrees of freedom | Reported: 11 |
| Pinch force | Reported: ≥15N |
| Control precision | Reported: 0.1° |
| Thumb motion distribution | Reported: two active DOF for abduction and adduction, plus one passive flexion/extension DOF |
| Other finger motion distribution | Reported: each of the other four fingers has one active and one passive flexion/extension DOF |
| Communication interfaces | Reported for Pro and Touch: RS485, CAN FD, EtherCAT |
| Interface location | Reported for Pro and Touch: below the wrist |
| Software support | Reported SDK support for Linux, Windows, and ROS workflows |
| Control and protections | Reported closed-loop servo control, custom gesture definitions, and protections for current, stall, high temperature, and collision |
| Default left-hand device ID | Reported: 126 |
| Box contents | Not published; confirmed at quotation |
| IP rating | Not published; confirmed at quotation |
| Cable length | Not published; confirmed at quotation |
| Fingertip force resolution | Not published; confirmed at quotation |
| Material | Not published; confirmed at quotation |
Specifications are as published and are confirmed against the datasheet at quotation.
How does the XTL fit a robot control system?
The published specification reports RS485, CAN FD, and EtherCAT communication for Pro and Touch, with the interface below the wrist. This gives an integration team documented interface options to assess, rather than a basis for assuming immediate compatibility with an existing controller. Electrical connection details, protocol implementation, and the required software path should be checked before committing the surrounding system design.
SDK support for Linux, Windows, and ROS workflows is also reported. That is useful for teams working across research and development environments, but it is not a statement that every operating-system release or ROS setup is supported. Ask Robots USA to confirm the relevant software documentation at quotation. The reported default left-hand device ID of 126 should likewise be checked when planning device addressing.
Mechanical integration deserves a separate review. An interface below the wrist does not establish the mounting geometry, required clearance, or cable routing for a particular robot. Supplying the intended mounting arrangement with the quotation request helps keep those questions visible instead of treating communication support as complete system compatibility.
What should buyers verify about the Touch version?
The published version table identifies Touch as XTL/XTR, but the supplied fact sheet does not specify a tactile sensor architecture or fingertip force resolution. The manufacturer has not published fingertip force resolution in the supplied sources; it is confirmed at quotation. Buyers whose experiments depend on contact measurements should therefore request the relevant sensing documentation before defining their test method.
The reported pinch force of ≥15N and control precision of 0.1° answer different questions. Neither establishes a whole-hand lifting payload, object-position accuracy, or contact measurement accuracy. A useful evaluation separates commanded motion, grasp retention, and sensing requirements, then asks for evidence relevant to each. This avoids turning a published control figure into an unsupported task-performance claim.
Who is Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) for?
This hand is a candidate for robotics laboratories, manipulation researchers, and engineering teams assessing an articulated left-hand assembly. The published description supports robot integration and research as its role. In those settings, buyers typically need to connect hardware, create repeatable commands, and compare outcomes against their own experimental criteria rather than assume a finished application.
For a right-side requirement, review the Brainco Revo 2 Touch Biomimetic Dexterous Right Hand (XTR) rather than treating XTL as interchangeable. The available evidence does not establish that Basic or Pro is better for a particular budget or task. Broader selection within the BrainCo Revo 2 category should follow a documented comparison, especially where sensing requirements determine the choice.
What is Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) used for?
- Robot integration research: Evaluate an articulated hand within a proposed robot architecture.
- Gesture development: Investigate command sequences using the reported custom gesture definitions.
- Grasping experiments: Study interaction with representative objects under a controlled test procedure.
- Control workflow evaluation: Assess the reported SDK support against the project's software environment.
- Communication integration: Review the reported interface options against the chosen controller.
- Left-hand platform development: Assess side-specific integration needs before finalizing a robotic assembly.
Pricing and Availability
Request a quotation from Robots USA for the XTL configuration and the documentation needed to assess it. Include the application, controller, mounting concept, and any sensing requirements. The manufacturer has not published box contents, cable length, IP rating, or material in the supplied sources; these are confirmed at quotation.
Robots USA arranges delivery, customs, and support with the quotation. To begin a configuration and scope-of-supply review, use the quotation request available on this page.
Frequently Asked Questions
Is this the left-hand Touch configuration?
Yes, the product identity specifies the left-hand XTL configuration. The published version listing reports XTL/XTR for Touch; do not substitute a right-hand reference when requesting this product.
How many joints and degrees of freedom are reported?
The published specification reports 6 active joints and 11 degrees of freedom. The documented motion distribution includes active and passive movement, so these figures are not equivalent counts of independently controlled axes.
Which communication interfaces are listed?
Per the published specification, Pro and Touch support RS485, CAN FD, and EtherCAT, with the interface below the wrist. Confirm the connection and protocol requirements for your controller at quotation.
Can it be evaluated in a ROS workflow?
The source reports SDK support for Linux, Windows, and ROS workflows. Specific software versions and integration requirements should be confirmed before selecting the development environment.
Does the available specification establish tactile measurement performance?
No tactile measurement performance is established by the supplied fact sheet. The manufacturer has not published fingertip force resolution in the supplied sources; it is confirmed at quotation.
Are operating protections and environmental protection the same?
No. The source reports protections for current, stall, high temperature, and collision, but the manufacturer has not published an IP rating in the supplied sources; it is confirmed at quotation.
Where can I buy Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) and what does it cost?
Request a quotation from Robots USA through this page. The quotation establishes the selected configuration, scope of supply, and delivery, customs, and support arrangements without relying on an assumed package.
Summary
The wrist is an integration boundary, not just a mounting point. For this XTL hand, the published evidence supports a review of articulation, control, communication, and software requirements, while important package and sensing details still require confirmation. Bring those requirements to Robots USA before finalizing the surrounding robot design; this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
What's included
Videos